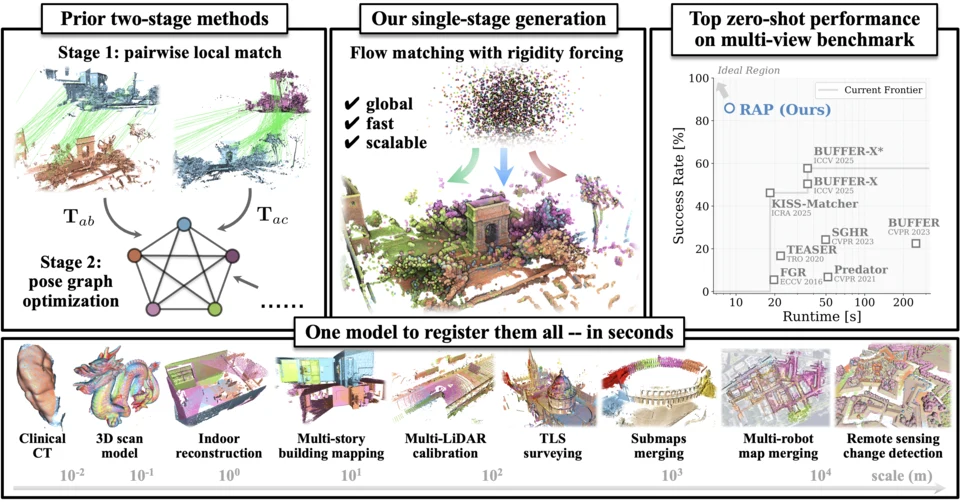
Register Any Point: Scaling 3D Point Cloud Registration by Flow Matching
A single flow-matching model for pairwise and multi-view registration, generalizing across scene scales and sensor modalities.
* Equal contribution
A single flow-matching model for pairwise and multi-view registration, generalizing across scene scales and sensor modalities.
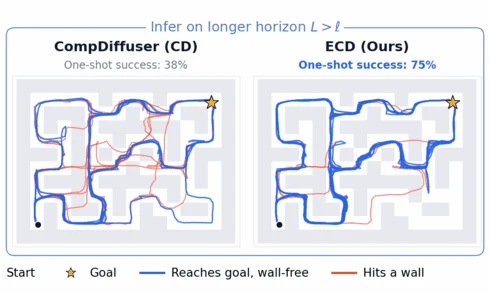
Composing short trajectory fragments into coherent long-horizon robot plans with a global energy and consistent boundary corrections.
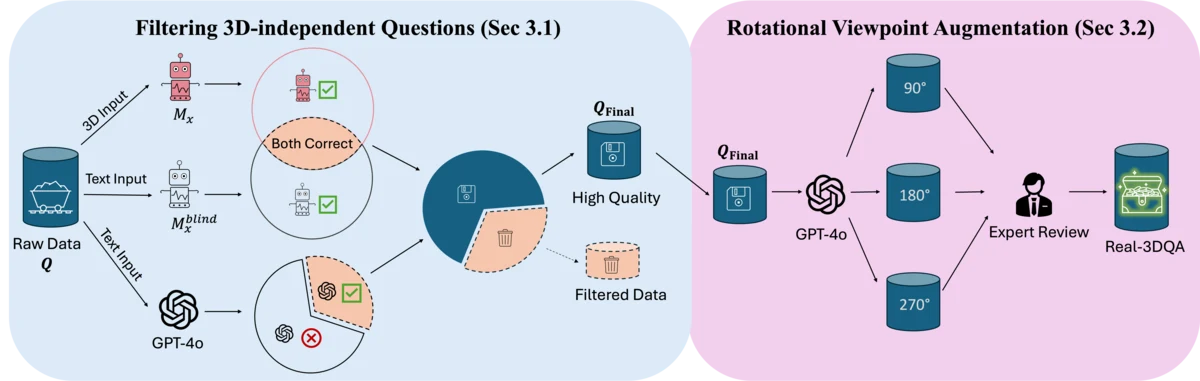
Exposing language shortcuts in 3D reasoning benchmarks and introducing Real-3DQA to test whether models actually use visual geometry.
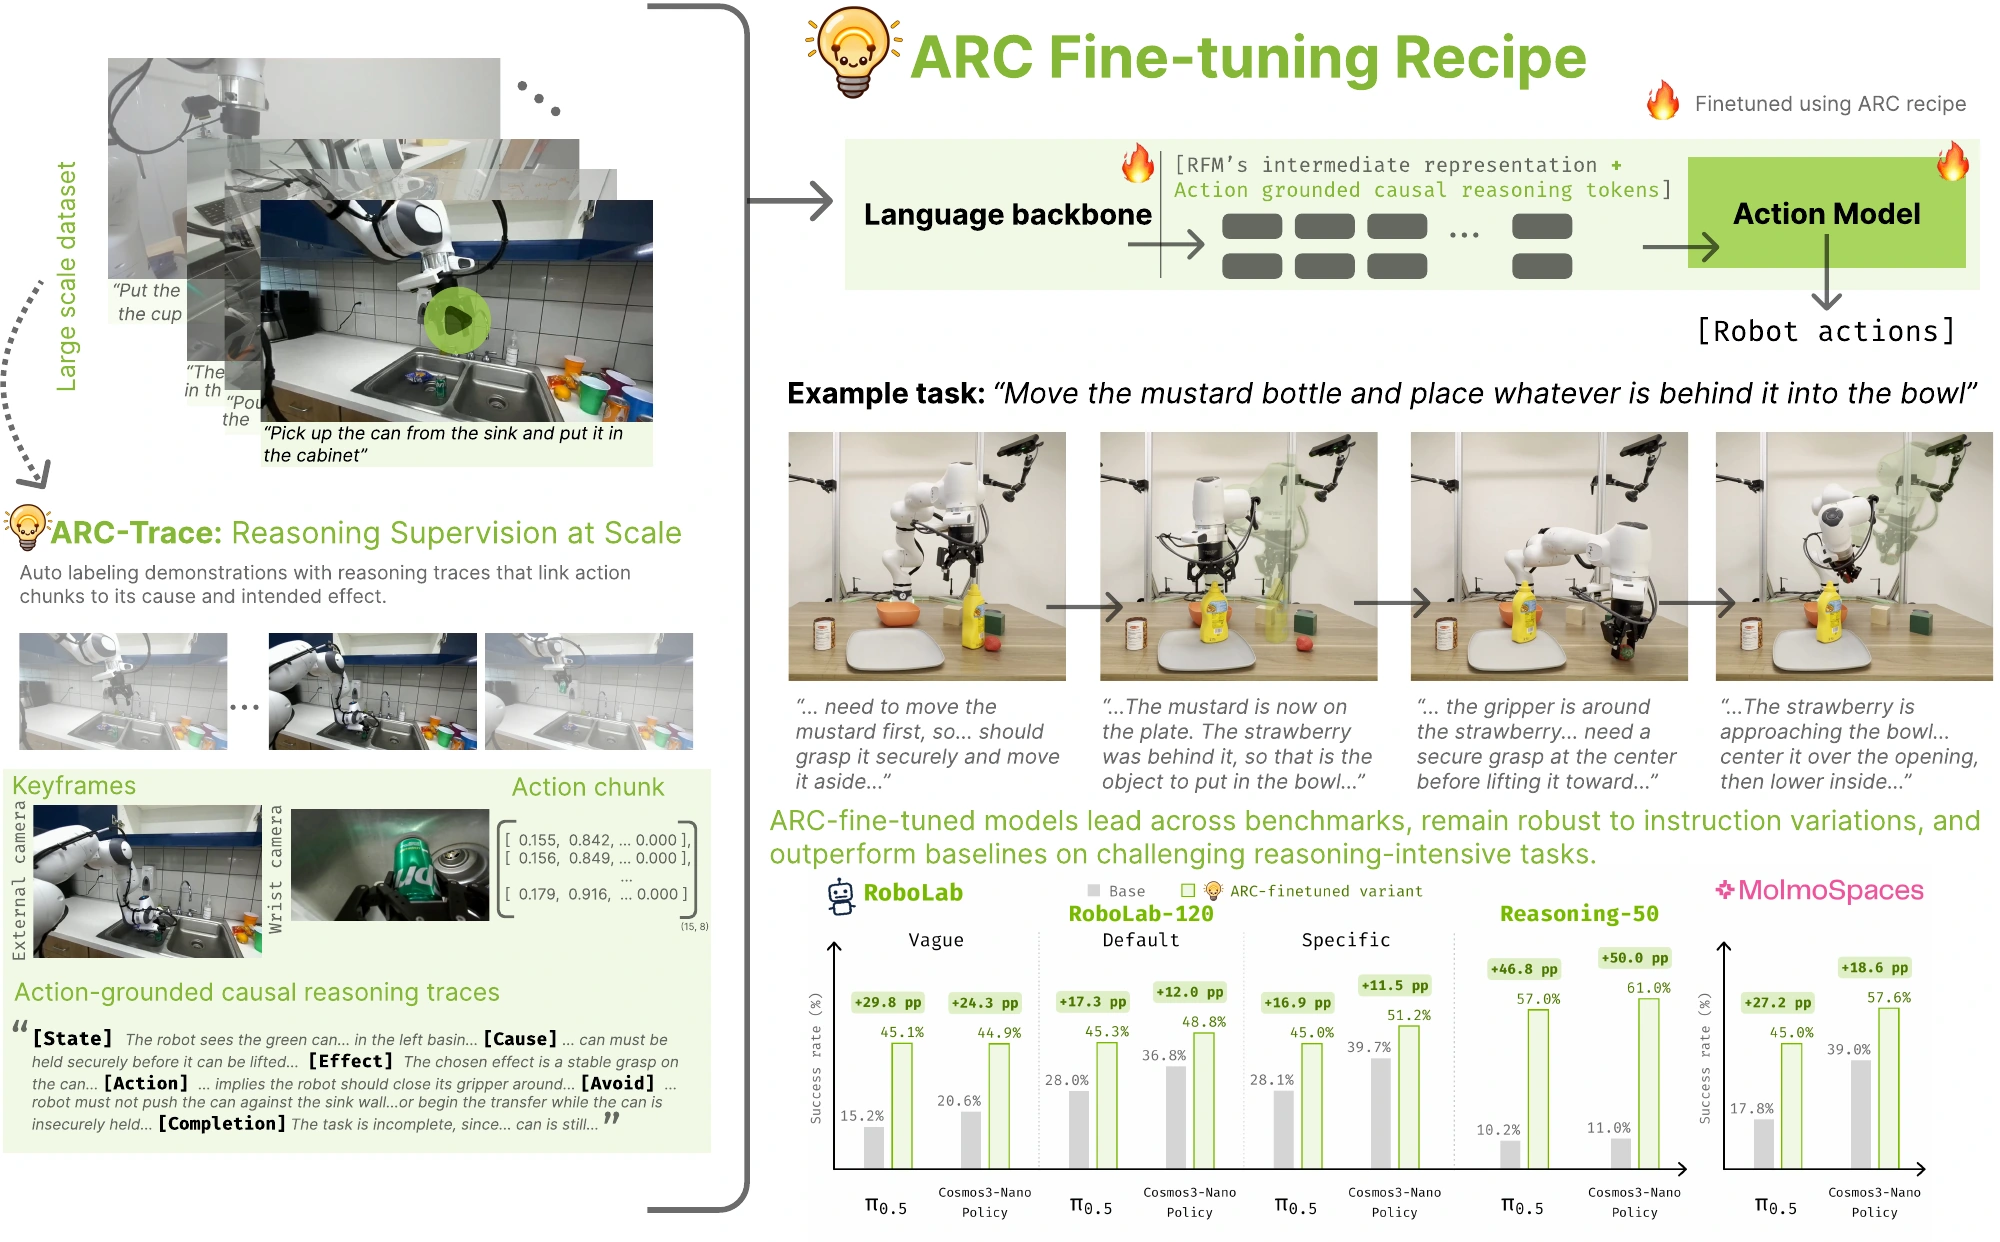
Action-grounded causal reasoning improves robot foundation models using automatically labeled existing demonstrations.
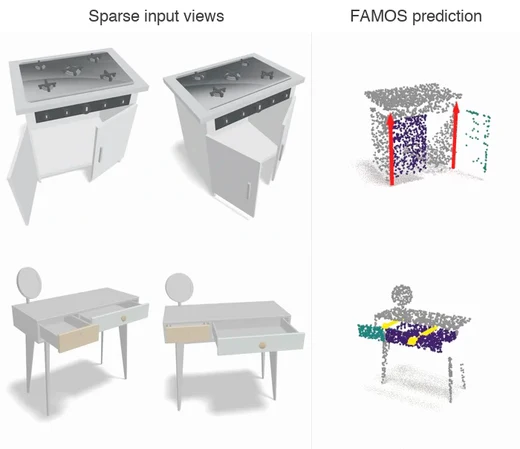
A feed-forward model that predicts movable parts and joint parameters of articulated objects from a sparse, unordered set of partial point clouds.
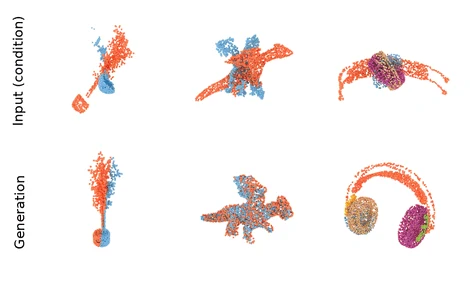
One generative formulation for point cloud registration and multi-part assembly, learning geometric symmetries without symmetry labels.
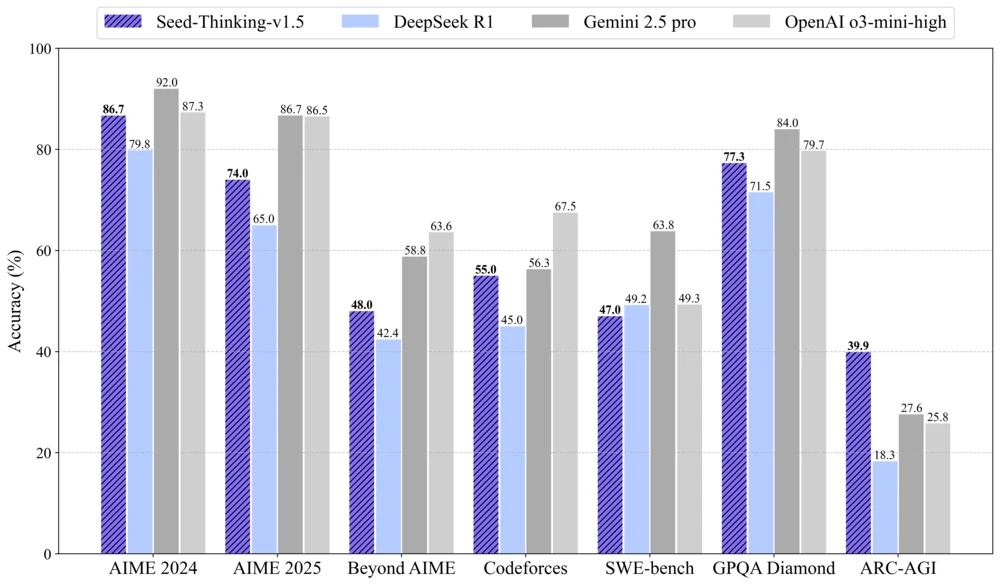
Scaling reasoning through reinforcement learning, with advances in training data, reward modeling, algorithms, and distributed infrastructure.
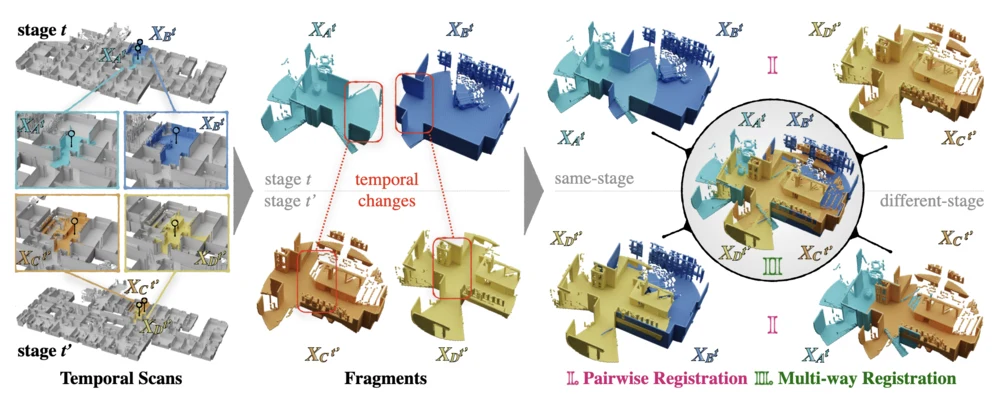
A real-world benchmark for aligning 3D scenes across construction and renovation, with large structural and temporal changes.
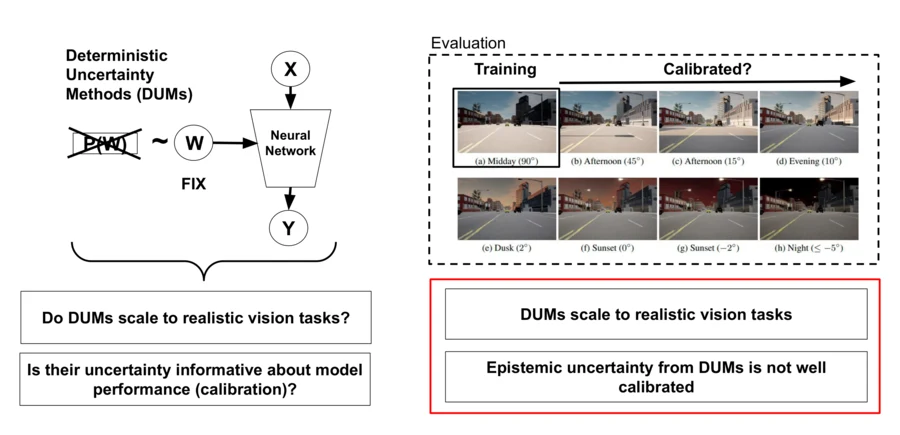
Testing whether deterministic uncertainty estimates remain reliable under distribution shifts and in dense prediction tasks.
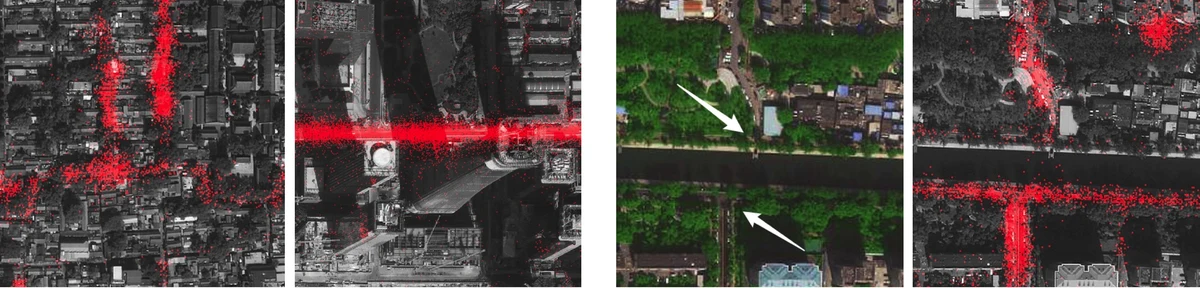
Leveraging crowdsourced GPS data to improve and support road extraction from aerial imagery.
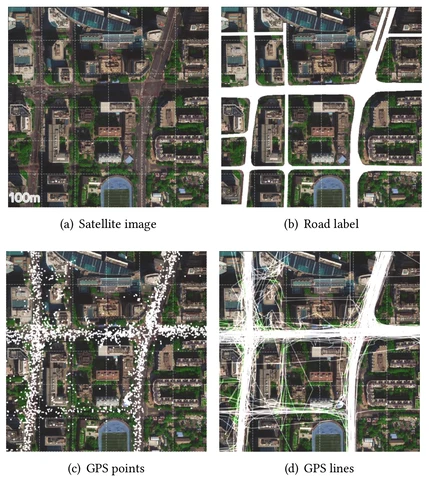
Combining satellite imagery with GPS data to improve road extraction quality
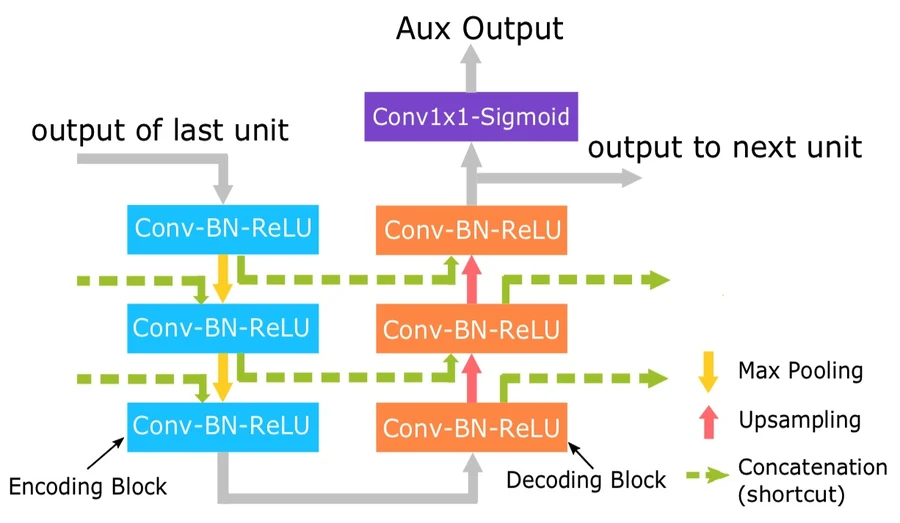
Stacked U-Nets, auxiliary supervision, and topology-aware post-processing for extracting connected roads from satellite imagery.