ARC: A Reasoning Recipe for Robot Foundation Models
arXiv:2610.12386
Abstract
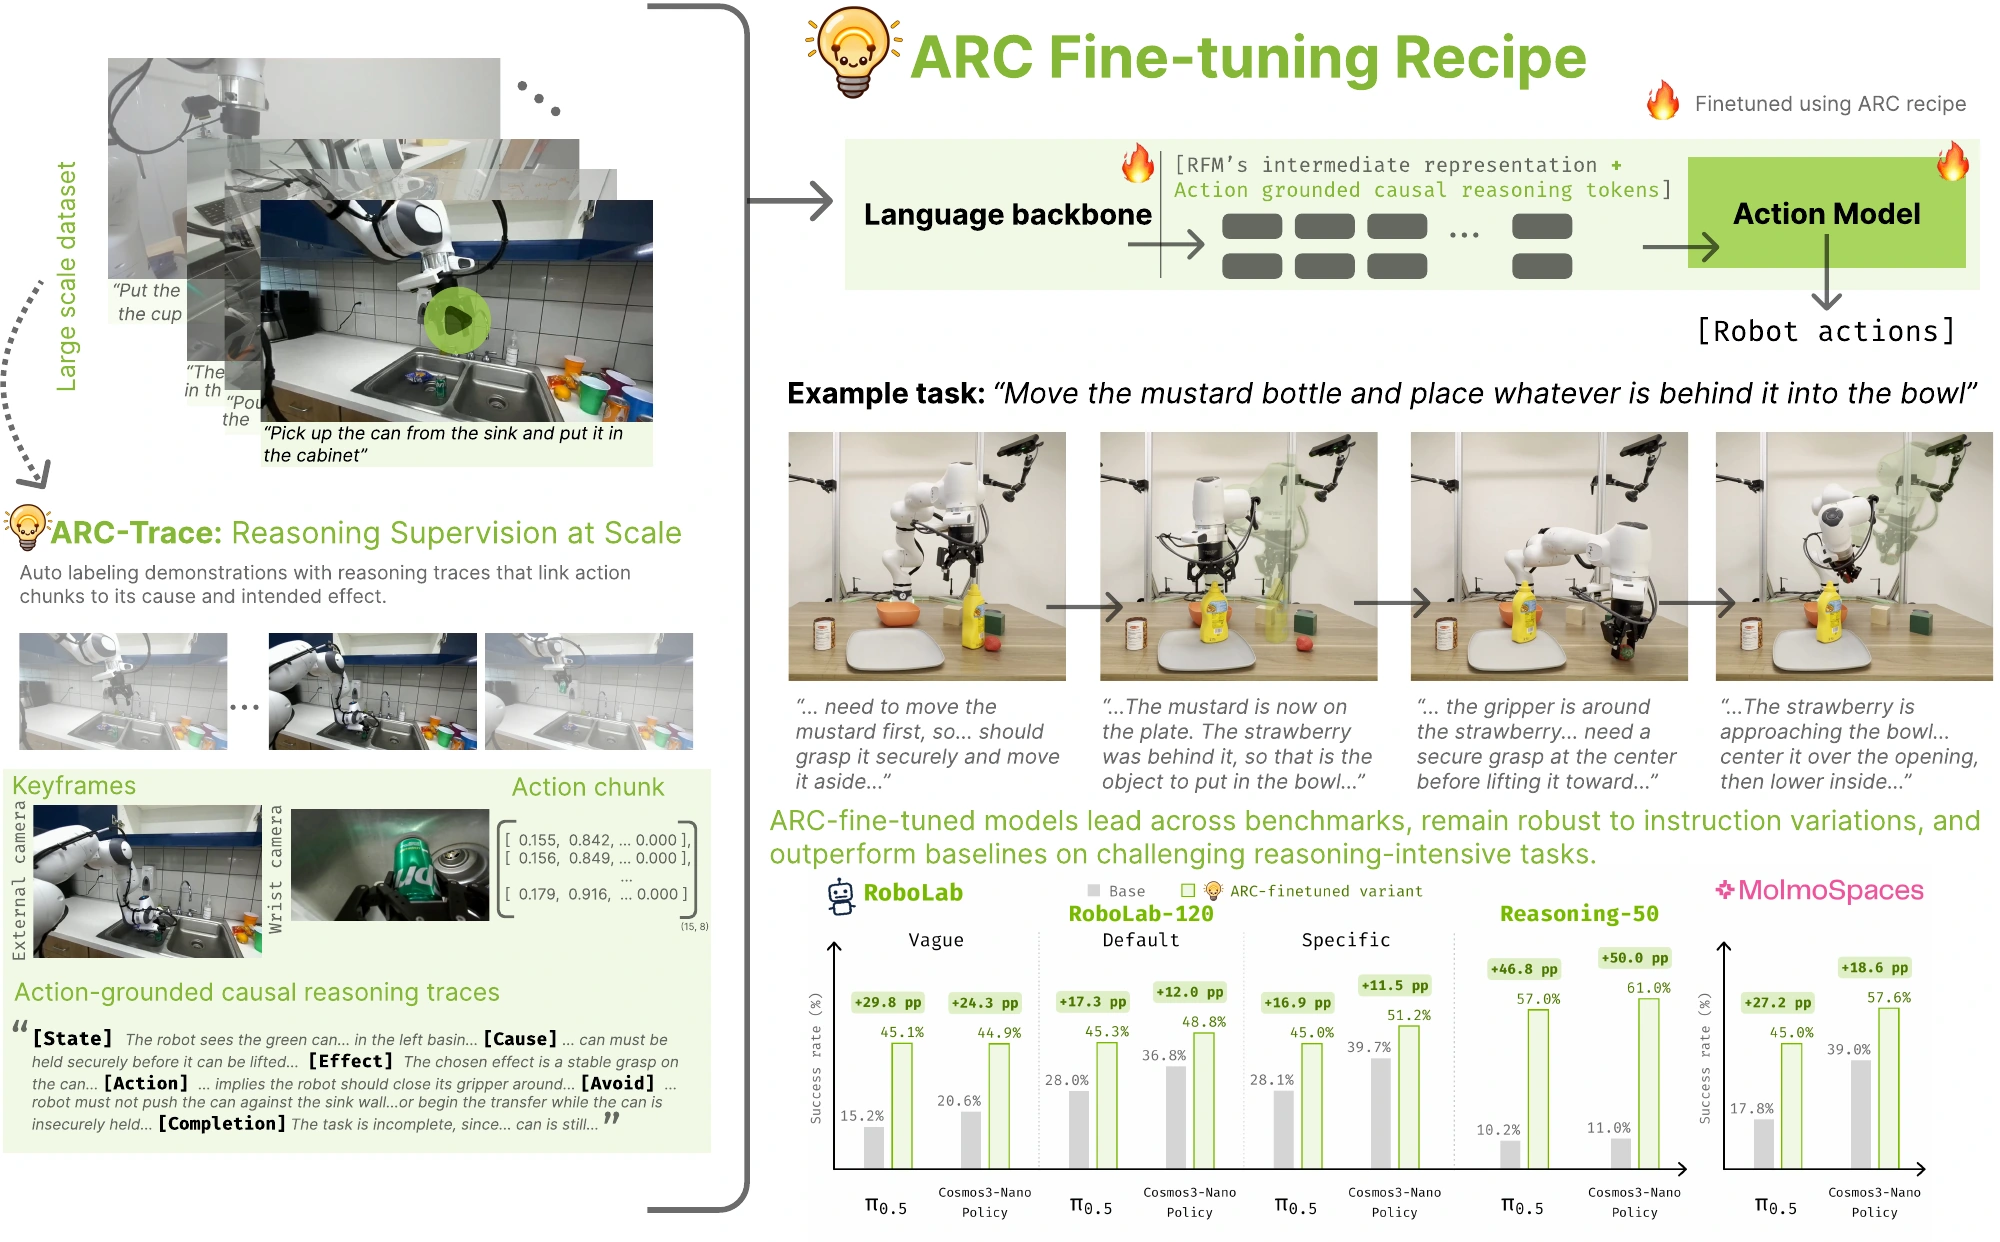
ARC improves robot foundation models by teaching them to reason about the causes and expected effects of their next actions. It combines action-grounded reasoning traces, an automatic pipeline for labeling existing demonstrations, and model-specific adaptation strategies. The pipeline produces ARC-Trace-DROID without collecting additional robot data. ARC adapts both vision-language-action models, including π₀.₅, and world-action models, including Cosmos3-Nano-Policy. The adapted models achieve state-of-the-art results on RoboLab-120 and MolmoSpaces, with gains of up to 50 percentage points on RoboLab-Reasoning-50. Real-robot experiments improve π₀.₅ task success by 82.2 percentage points, without additional robot demonstrations or foundation-scale training.
BibTeX
@article{puthumanaillam2026arc,
  title={ARC: A Reasoning Recipe for Robot Foundation Models},
  author={Puthumanaillam, Gokul and Sun, Tao and Aljalbout, Elie and Reuss, Moritz and Li, Zhaoshuo and Ramos, Fabio and Goyal, Ankit and Yang, Jenai Xuning},
  journal={arXiv preprint arXiv:2610.12386},
  year={2026},
  doi={10.48550/arXiv.2610.12386},
  url={https://arxiv.org/abs/2610.12386}
}