Energy-based Compositional Diffusion Planning
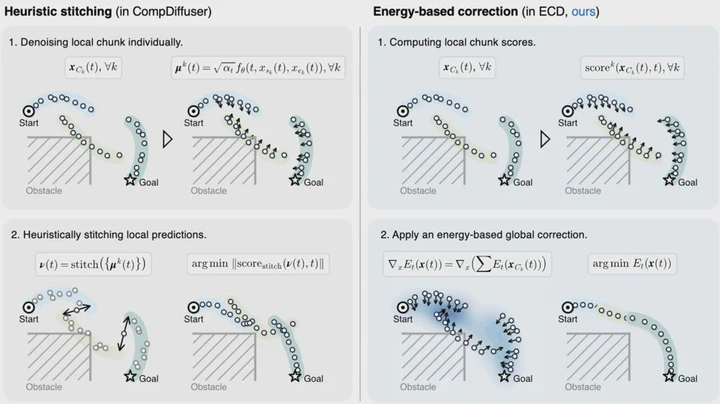 Energy-based composition corrects the boundaries between short trajectory fragments.
Abstract
Energy-based Compositional Diffuser (ECD) composes short diffusion-generated trajectory fragments into long-horizon robot plans. It defines a global trajectory energy whose gradient corrects inconsistencies at fragment boundaries. An efficient Markov-based approximation keeps inference cost linear in the planning horizon. Experiments on OGBench stitching tasks evaluate planning success and inference efficiency.
Type
Publication
International Conference on Machine Learning (ICML) 2026