Register Any Point: Scaling 3D Point Cloud Registration by Flow Matching
European Conference on Computer Vision (ECCV) 2026
Abstract
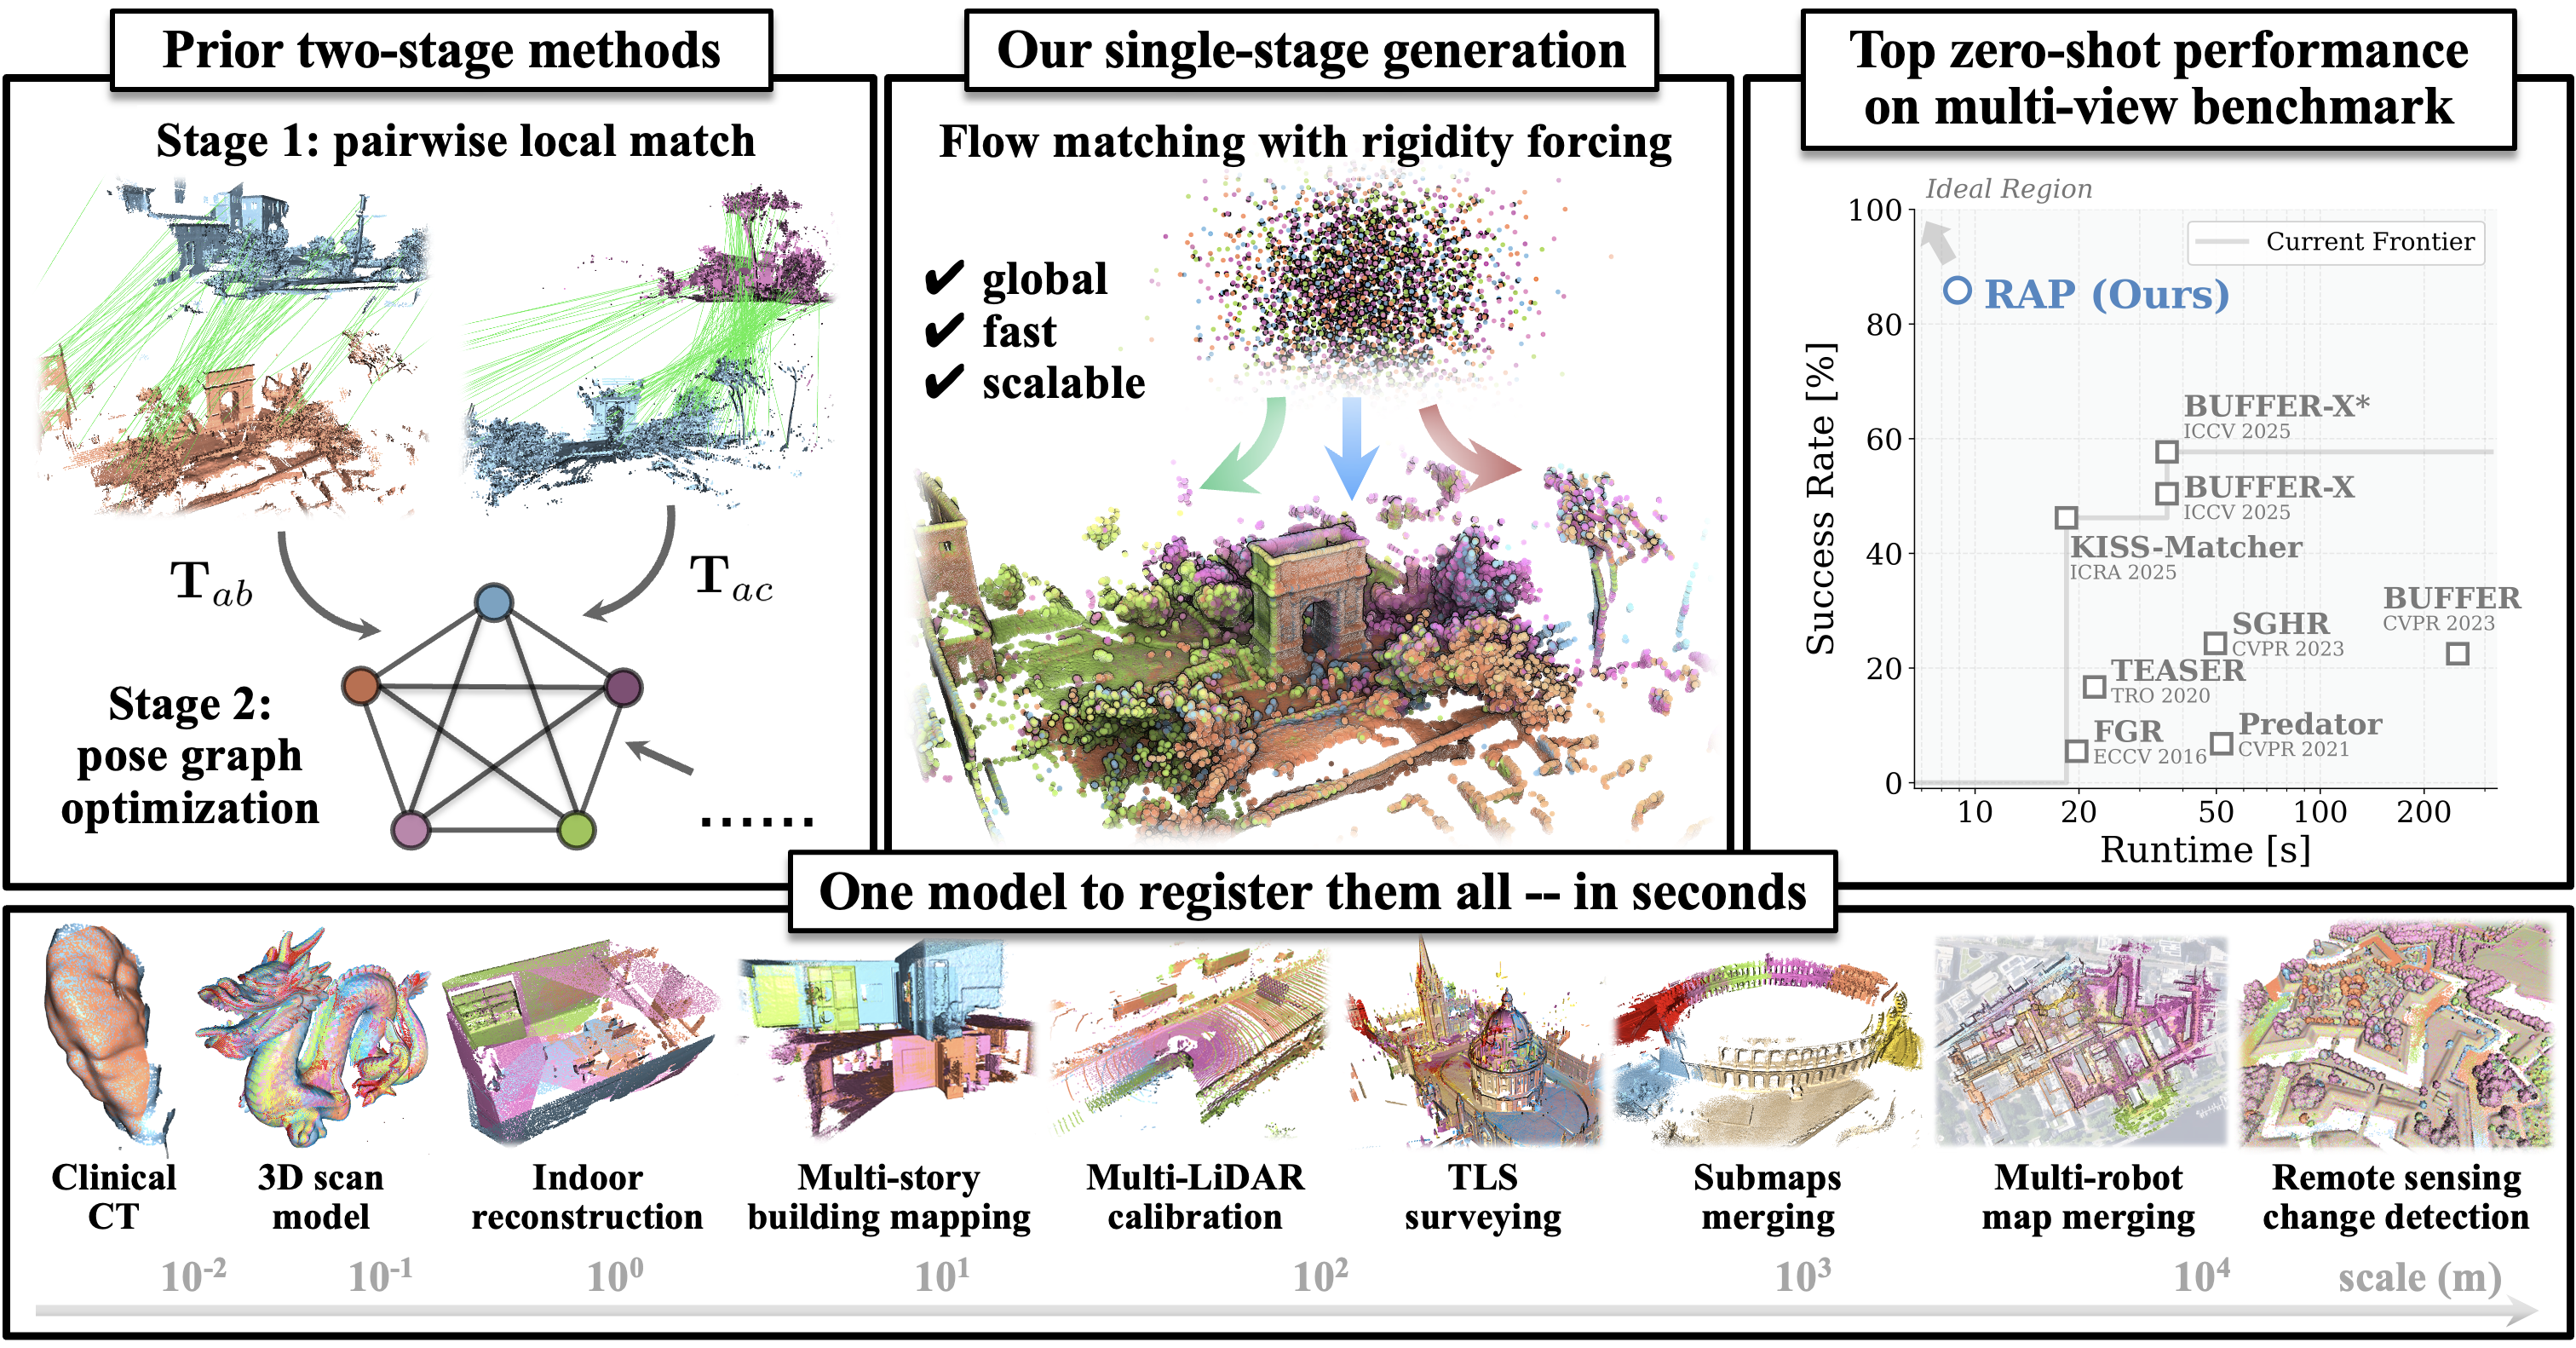
Point cloud registration aligns multiple unposed point clouds into a common frame, a core capability for 3D reconstruction and robot localization. We cast registration as conditional generation: a learned continuous point-wise velocity field transports noisy points to a registered scene, from which the pose of each view is recovered. The resulting model performs strongly across pairwise and multi-view registration benchmarks, particularly under low overlap, and generalizes across scales and sensor modalities.
BibTeX
@inproceedings{pan2026rap,
  title={Register Any Point: Scaling 3D Point Cloud Registration by Flow Matching},
  author={Pan, Yue and Sun, Tao and Zhu, Liyuan and Nunes, Lucas and Armeni, Iro and Behley, Jens and Stachniss, Cyrill},
  booktitle={European Conference on Computer Vision},
  year={2026},
  url={https://arxiv.org/abs/2512.01850}
}